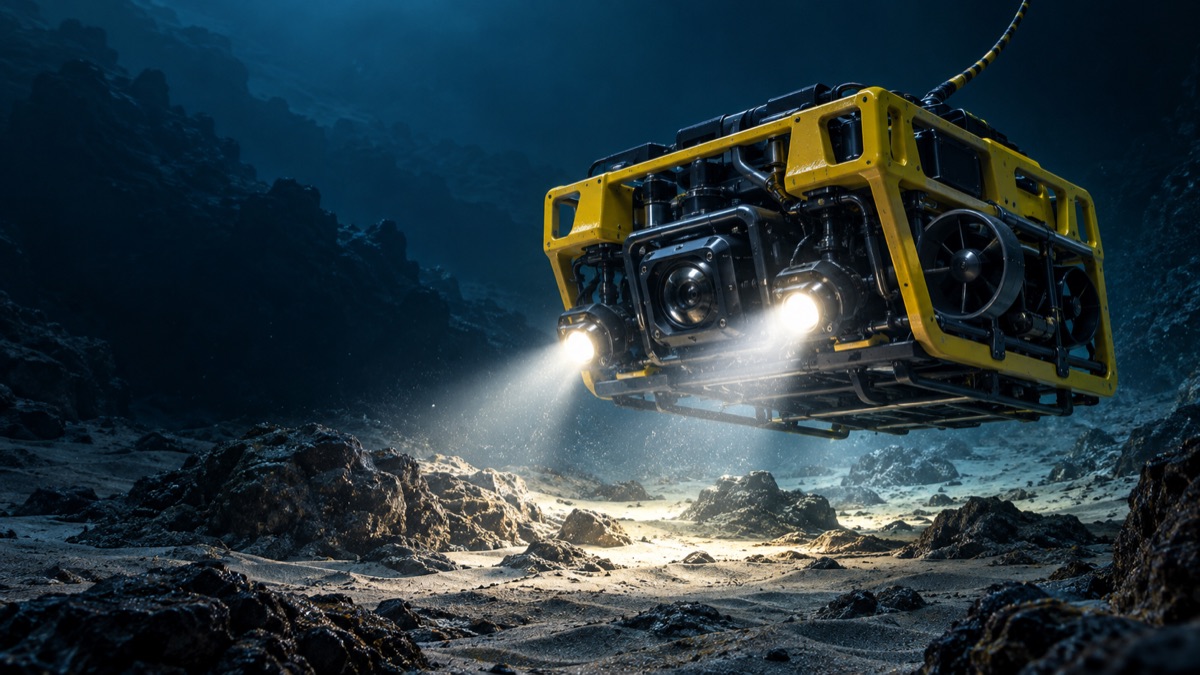
An underwater ROV operator simulator. Pilot a tethered remotely operated vehicle over the seabed, seeing the world only through its cameras and instruments, like the operators who explore the deep ocean for real.
Early prototype. Not yet available. No price, release date or store page has been set.
Being built
What ARONOX is about
Three onboard cameras
Forward, down and rear cameras all look into the same underwater world, so a rock you pass ahead shows up below and then behind you.
An operator's console
Steer by depth, altitude above the seabed, heading and attitude from a telemetry console, not a third-person camera.
The tether matters
The vehicle stays connected to the surface. When the simulated link drops, the video freezes, just as a real operator would see it.
Built for multiple monitors
Play on one screen, or spread the console and camera views across two or three monitors, with layouts that check how many displays you have.
An instructor station
A separate simulation-control view shows what's really happening under the water, designed for a second person or a second monitor.
Mac and Windows
Prototype builds are made for Apple Silicon Macs and 64-bit Windows. Testing on Windows and multi-monitor setups is ongoing.
Honest status
- Early prototype. Core camera, console and multi-monitor systems exist. Much of the simulation is still illustrative.
- A generic training seabed. The underwater world isn't a real location, and has no sea life yet.
- Illustrative water and physics. Lighting, visibility and vehicle response are tuned to feel right, not calibrated to real equipment.
- A game, not certification. ARONOX is inspired by real ROV operations. It isn't a professional training or qualification tool.
- Built with AI agents. Like other JymboAI projects, ARONOX is being developed with AI assistance and human review. Build updates will appear on the blog.